Autonomous Vehicle Companies
Distributed perception where connectivity is intermittent
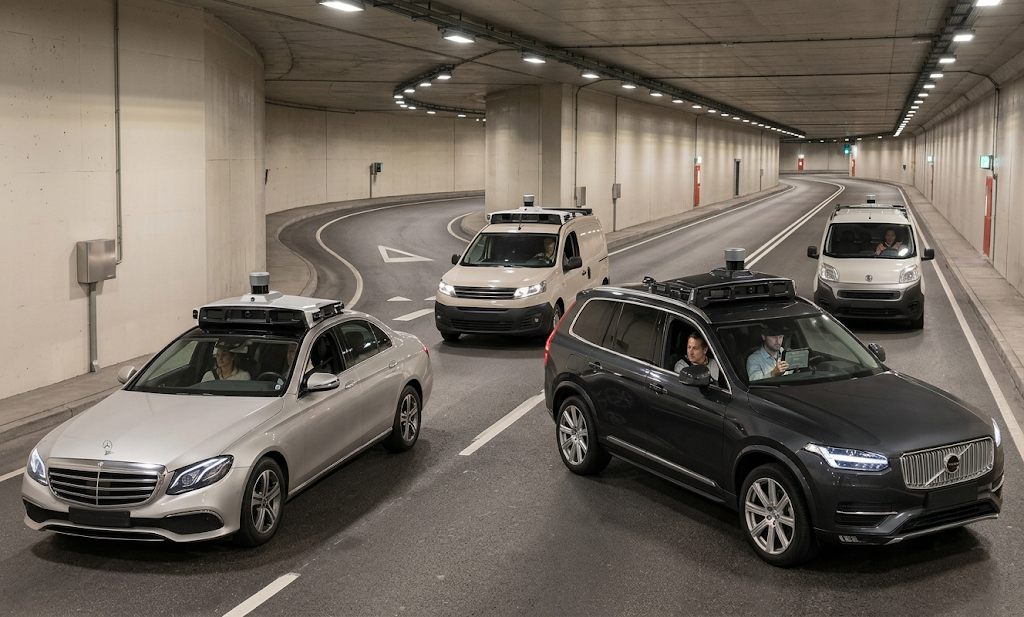
Fleet-scale edge AI for ADAS validation, teleoperation assist, and depot autonomy with secure model distribution.
“An autonomy program is only as trustworthy as its answer to one question: which software is running on which vehicle right now?”
Autonomous vehicle programs generate enormous sensor volumes, a single vehicle with LiDAR, radar, and a full camera ring can produce terabytes per shift. But not every decision belongs in the cloud, and not every byte deserves an uplink. Depot maneuvers, remote assist handoffs, and safety-critical perception stacks benefit from low-latency edge compute aboard the vehicle or at fixed edge nodes along depots, ports, and dedicated routes.
Aerbix supports secure over-the-air model delivery, encrypted telemetry, and fleet topology views so autonomy teams can reason precisely about which software build is running on which vehicle, a requirement that becomes non-negotiable during homologation, insurance negotiations, and incident review.
The connectivity myth
Program plans often assume continuous 5G coverage; operations quickly learn otherwise. Cellular dead zones inside parking structures, metal-clad depots, tunnels, and rural highway segments are routine. An architecture that depends on the cloud for perception or control simply fails in these environments, which is why serious programs treat the vehicle as a self-sufficient edge node and the cloud as a coordination and analytics layer.
Data economics push in the same direction. Uploading raw LiDAR point clouds at fleet scale is prohibitively expensive, and strict data residency rules in many jurisdictions constrain where captured street imagery may travel. Edge-first architectures keep inference local by default, uploading only curated events: disengagements, near-miss captures, rare-object detections, and the statistical summaries that feed continuous training pipelines.
Managing builds across a mixed fleet
Real fleets are heterogeneous. Development mules run experimental stacks, validation vehicles run release candidates, and revenue-service vehicles run certified builds, often across multiple hardware revisions. Aerbix models this as fleet cohorts with independent release channels, so a perception update can bake on twenty validation vehicles for two weeks before any customer-facing vehicle sees it.
Every deployment is cryptographically signed, versioned, and attested. When a regulator or internal safety board asks what changed between two dates, the answer is a query, not an archaeology project. Rollbacks are equally deliberate: if telemetry shows a regression in a specific operational design domain, say, degraded pedestrian detection at dusk, the affected cohort reverts while the rest of the fleet continues unaffected.
Beyond the vehicle
Autonomy programs increasingly extend intelligence into infrastructure: depot cameras that choreograph parking and charging, roadside units that extend perception around blind corners, and teleoperation centers that need trustworthy, low-latency vehicle state. Aerbix manages these fixed edge nodes with the same tooling as the vehicles themselves, giving program managers one coherent operational picture.
The programs that reach commercial scale are not necessarily the ones with the flashiest demos; they are the ones whose software operations are boring, auditable, and repeatable. That is the discipline an edge fleet platform exists to provide.
For autonomy leaders planning their next phase, the practical starting point is an honest inventory: how many software configurations exist across the fleet today, how long a full-fleet update takes, and how quickly a bad build can be detected and reversed. Improving those three numbers does more for commercial readiness than almost any perception benchmark, and it is precisely the work Aerbix was built to accelerate.
Discuss this deployment
Our solutions team helps map Aerbix to your fleet, licensing model, and integration requirements.
Talk to Aerbix